FusionCore verification study
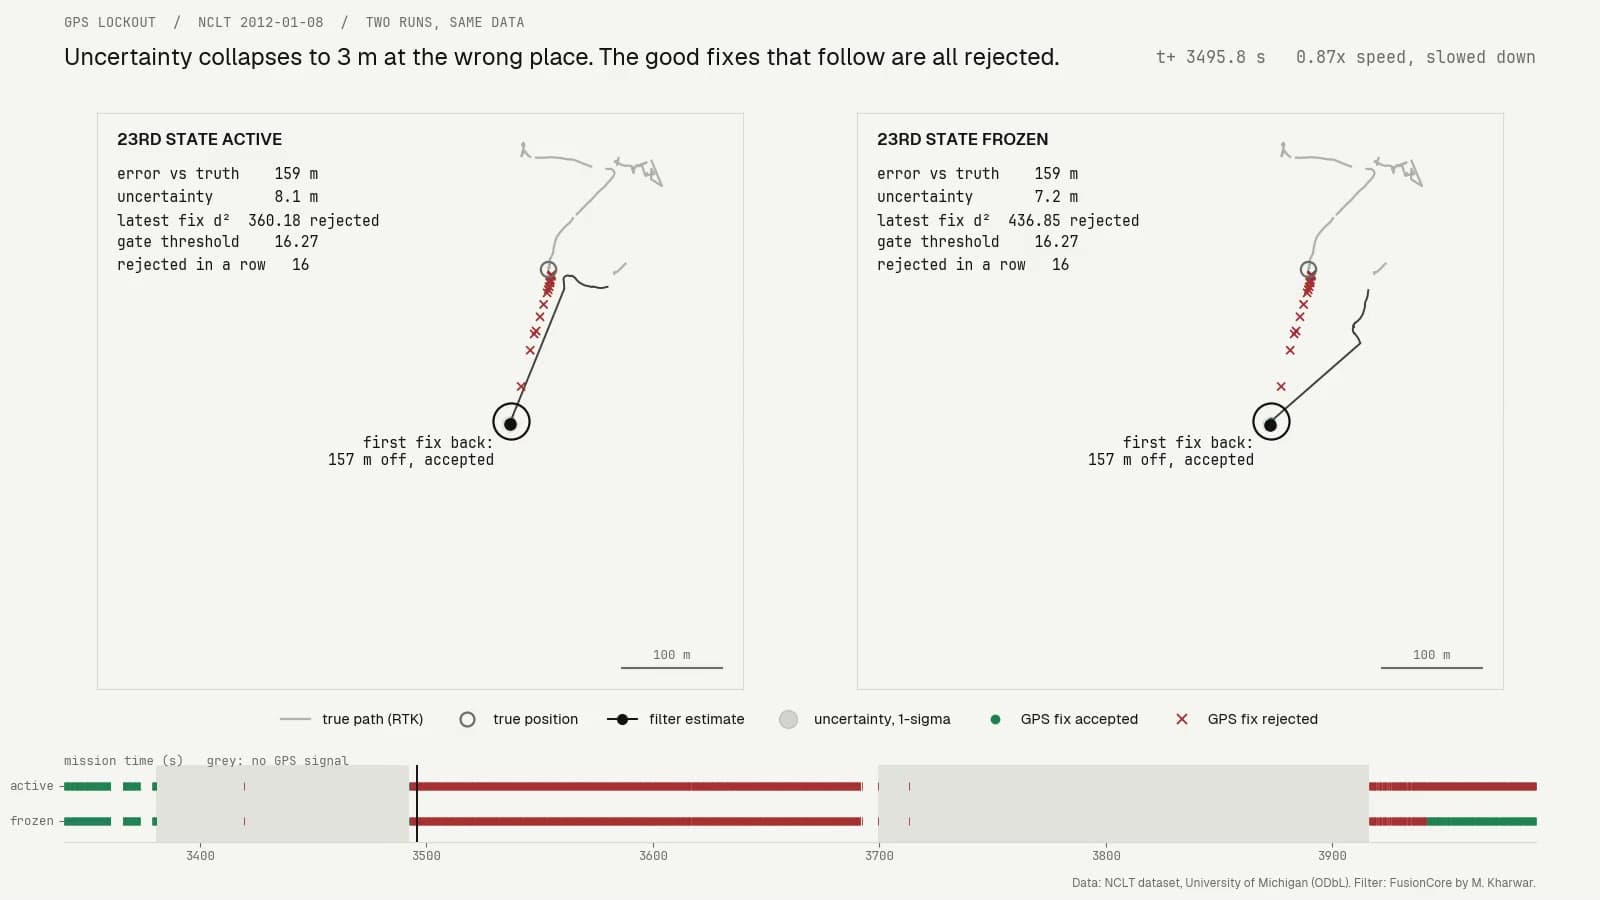
Testing three claims from a published ROS 2 sensor-fusion paper against its code and data. Two did not hold up; the third did, on a sequence the paper didn't examine.
State estimation and control for mobile robots.
I'm a third-year Robotics & Mechatronics Engineering student at the University of Sheffield. I work on the software side of robots: state estimation, control, and the algorithms that decide where a robot is and how it should move. My most recent project is an independent verification study of FusionCore, an open-source sensor-fusion filter for ROS 2.
Testing three claims from a published ROS 2 sensor-fusion paper against its code and data. Two did not hold up; the third did, on a sequence the paper didn't examine.